Part 1: System cardDel 1: Systemkort
1. Core Function
Hybrid diesel-electric podded propulsion decouples prime movers from propellers by generating electricity centrally with diesel generators and Lithium-Ion batteries feeding a shared AC or DC switchboard1. A Power Management System optimizes engine loading while Variable Frequency Drives power 360-degree steerable azimuth thrusters or gearless submerged pods (Azipods)4. Central electrification enables peak shaving, zero-emission port or fjord transit, and omnidirectional vectored thrust for superior maneuverability and efficiency without rudders or shaftlines1.
2. Primary Operational Tasks
- Variable-load power plant optimization: Automatically starting, stopping, and load-sharing diesel generator sets via the Power Management System—or varying engine RPM on DC-grid vessels—to hold combustion engines within their optimal 60–85% Specific Fuel Oil Consumption (SFOC) band1.
- Peak shaving and spinning reserve: Discharging Lithium-Ion Energy Storage Systems (ESS) to absorb rapid Dynamic Positioning (DP), winch, or crane load spikes and provide instantaneous fault-ride-through backup, reducing running engine count and maintenance hours3.
- Zero-emission harbor and fjord operation: Disconnecting combustion engines to run solely on battery energy during port maneuvers, standby, and transit through zero-emission zones such as Norway's UNESCO World Heritage fjords8.
- 360-degree omnidirectional thrust vectoring: Slewing external thruster units across full 360° arcs for rapid crash stops, lateral crabbing, on-the-spot pivoting, and precise station-keeping without conventional rudders6.
- Regenerative energy harvesting: Returning reverse electrical power from active-heave crane lowering, winch payout, or propulsion braking onto the DC busbar to recharge batteries13.
3. System Interconnections
Inputs: Electrical power enters from fixed-speed (50/60 Hz) or variable-speed diesel and dual-fuel generator sets connected to High-Voltage (HV) or Low-Voltage (LV) Main Switchboards (commonly 690 VAC, medium-voltage AC, or 1,000 VDC Onboard DC Grid busbars)1. Shore charging connects via High-Voltage Shore Connections (HVSC ≥1 MVA under IEC/IEEE 80005-1) or Low-Voltage Shore Connections (LVSC <1 MVA under IEC/IEEE 80005-3) governed by IEC/IEEE 80005-2 safety and data loops19. Power conversion occurs across multi-pulse phase-shifting transformers or Active Front-End (AFE) IGBT rectifiers supplying Variable Frequency Drive (VFD) DC-link busbars5. Command inputs originate from bridge manual remote controls, Dynamic Positioning (DP) thrust allocators, waypoint/target-tracking modes, and PMS/EMS dispatch loops (dedicated joystick and conventional autopilot interface hardware protocols are not specifically detailed in the reviewed technical documentation)7.
Outputs: Mechanical outputs deliver continuous 360° hydrodynamic thrust via pulling or pushing propellers (open or ducted nozzles)25. Four-quadrant drives feed regenerative braking power back to the ESS or dissipate steering reverse energy into brake resistor banks16. Losses reject heat into Low-Temperature (LT) fresh-water cooling circuits, machinery-room air, or directly by convection to seawater in compact pods26. Diagnostic telemetry streams Battery Management System (BMS) state-of-charge, cell voltage, and temperature alarms, early off-gas (CO/H2) alerts, Insulation Monitoring Device (IMD) earth-fault readings, and steering encoder feedback to bridge and engine control stations34.
4. Redundancy & Criticality
Blackout prevention under SOLAS Safe Return to Port (SRtP) and Dynamic Positioning rules (DP2/DP3) segregates switchboards into physically separated fire and watertight redundancy zones via open bus-tie breakers so no single active failure (DP2) or single-compartment fire or flood (DP3) causes loss of position, whereas SRtP requires retaining propulsion, steering, and navigation for at least three hours to return to port after a fire-zone casualty12. Where closed bus-ties operate for efficiency (e.g., DNV RP-0591, IRS Closed Bus-Tie Guidelines), class rules require open-bus fallback, Failure Mode and Effects Analysis (FMEA) proving trials, dual sync-check barriers, arcing fault discrimination, and Advanced Power System Protection (APSP)39. Automatic load shedding protects online gensets, and emergency power restoration must occur within 45 seconds of a blackout42.
To contain thermal runaway and explosive/toxic off-gassing in battery spaces, DNV GL Battery notation rules (Part 6, Chapter 2, Section 1) and Norwegian Maritime Authority (NMA) draft regulations (for Li-ion installations ≥20 kWh) require cell-level thermal propagation barriers, gastight boundaries (door leakage ≤0.5 m³/m²·h at 50 Pa), dedicated off-gas ducts routed ≥3.0 m clear of air intakes and muster stations, dual emergency-backed CO/H2 gas detectors, automatic shutdown of ventilation and non-explosion-proof gear on detection, and fixed fresh-water spray (≥5 L/min/m² for 60 minutes, or equivalent water mist) paired with inert-gas suppression34. For steering redundancy, SOLAS II-1/29 requires main gear movement from 35° one side to 30° opposite in ≤28 seconds—maintaining full capability under a single power-unit failure on passenger ships—and steering restoration within 45 seconds46; because SOLAS II-1/29 predates podded propulsors, class rules and IMO MSC.1/Circ.1398 adapt these criteria to multi-drive electric or hydraulic azimuth steering systems with fail-safe spring brakes and hot-standby dual control units17.
Part 2: Technical deep diveDel 2: Teknisk dybdeanalyse
1. Diesel-Electric Power Plant Architecture
Conventional marine diesel-electric vessels distribute three-phase AC power at fixed frequency (50 Hz or 60 Hz, typically 690 VAC on offshore vessels and ferries or 3.3–11 kV medium voltage on large cruise ships)1. Fixed grid frequency locks diesel prime movers to synchronous shaft speed defined by supply frequency ( ) and magnetic pole count (
 ):

Because rotational speed cannot drop when propulsion demand falls, engines operating during slow transit or Dynamic Positioning (DP) standby run heavily derated along the inefficient low-load region of their Specific Fuel Oil Consumption (SFOC) curve, whereas medium- and high-speed marine diesels typically achieve peak efficiency only within a narrow 60–85% rated load band (peaking near ~80–85% depending on engine make)10. Prolonged low-load operation promotes unburned soot build-up, lowers exhaust temperatures needed for Selective Catalytic Reduction (SCR) aftertreatment, and accelerates engine maintenance wear1.
Onboard DC-grid architectures—pioneered commercially by ABB's Onboard DC Grid on the MPSV Dina Star in March 2013 and scalable to at least 20 MW—reconfigure the plant as a vessel-wide distributed multidrive operating at a nominal 1,000 VDC2. Rectifying generator outputs directly onto a common DC busbar eliminates main AC switchboards, distributed drive rectifiers, and bulky phase-shifting converter transformers2. According to ABB engineering documentation and technical conference papers, replacing 690 VAC distribution with 1,000 VDC reduces electrical footprint and weight by up to 30%, cuts cabling requirements by up to ~40%, and improves electrical transmission efficiency by 0.5–1.0 percentage points1. Crucially, variable-speed gensets can reduce RPM smoothly at partial loads; ABB estimates partial-load SFOC drops of up to ~20% for medium-speed engines and ~40% for high-speed engines, alongside >5 dB noise reductions, up to 30% lower engine wear, and ~10-second high-speed genset connection without AC phase synchronization1. Across full offshore duty cycles integrated with batteries, ABB projects up to 20% total fuel savings (early 2014 brochure estimates cited up to 27% SFOC reduction)2, while ABB's intermediate Dynamic AC (DAC) variable-frequency AC concept targets ~6% annual fuel savings on cruise ships56; independent fleet-wide empirical benchmarks separating DC-grid savings from hybrid battery effects remain limited in the reviewed literature. Rather than standard AC breakers alone, ABB's DC-grid protection relies on coordinated selectivity combining fast fuses, isolating switches, and controlled semiconductor turn-off devices1.
Across both AC and DC plants, the Power Management System (PMS) governs real-time grid stability through load-dependent generator start/stop, power-band control, running-hour equalization, automatic synchronization, heavy-consumer start interlocking (bow thrusters, winches, cargo pumps), and fast load shedding or thruster load reduction4. Under closed-bus AC operation, one generator typically operates in isochronous mode to anchor frequency while online peers share load in droop mode40. On hybrid vessels, a supervisory Energy Management System (EMS) optimizes battery State of Charge (SoC) and voyage dispatch, though marine integration practice requires strict functional separation so EMS economic optimization cannot override PMS protection7. Traditional DP2/DP3 rules forced open bus-tie operation to isolate faults into separate redundancy groups, requiring extra idling gensets12. Contemporary closed bus-tie standards—including DNV RP-0591 (2024) with CB/CBT qualifiers and IRS December 2025 Closed Bus-Tie Guidelines (CLB, CLB-S, CLB-T)—permit unified bus-tie operation only when FMEA and live/simulated fault-ride-through (FRT) testing verify equivalent integrity, backed by Advanced Power System Protection (APSP) for arcing-fault discrimination, dual sync-check barriers in series, and dual bus-tie breakers (or dual semiconductor interrupting devices with isolating switches in DC architectures)39.
Shore power cold ironing interfaces with the main switchboard under the IEC/IEEE 80005 framework: Part 1 covers High-Voltage Shore Connections (HVSC ≥1 MVA or HV vessels), Part 3 covers Low-Voltage Shore Connections (LVSC <1 MVA), and Part 2 defines data communication, with standardized plugs under IEC 62613-2 (HV) and IEC 60309-5 (LV)19. Standards mandate galvanic isolation from the shore grid, onshore frequency conversion where frequencies differ, and a continuous ≥50 mA safety loop that opens both ship and shore circuit breakers within 200 ms if interrupted19. Under EU regulations, container and passenger vessels above 5,000 GT must connect to shore power (or use equivalent zero-emission power) at berth in TEN-T ports starting 1 January 2030, expanding to all EEA ports with shore facilities on 1 January 203519.
Propulsion and auxiliary Variable Frequency Drives (VFDs) using standard diode front-end rectifiers draw discontinuous current pulses rich in harmonic distortion22. An unfiltered 6-pulse VFD injects 35–80% current Total Harmonic Distortion (THDi)—typically dominated at 60 Hz full load by the 5th (20–30%, negative sequence causing reverse motor braking torque and heating), 7th (12–20%, positive sequence), 11th (6–10%, negative), and 13th (5–8%, positive) harmonics22. Because shipboard generators present higher subtransient impedance (lower short-circuit ratio Isc/IL) than land utility grids, harmonic currents induce severe voltage waveform distortion (THDv)61. Marine classification rules cap AC switchboard THDu below 8%, though individual-harmonic tolerances diverge: DNV, ABS, and KR enforce a flat <5% limit across all harmonic orders (including high orders such as the 49th), Lloyd's Register caps orders above the 25th at ≤1.5%, and Bureau Veritas caps ≤15th orders at 5% tapering logarithmically to 1% at the 100th order18. By comparison, IEEE 45-2002 specifies ≤8% THDv on dedicated propulsion buses and ≤5% THDv (≤3% individual) on general main buses, IEC 60034-1 caps THDv at 5% for synchronous motors >300 kW, and land-based IEEE 519-2022 limits PCC voltage distortion to 8% THDv (5% individual) at ≤1 kV and 5% THDv (3% individual) from 1–69 kV while scaling Total Demand Distortion (TDD) from 5% (Isc/IL < 20) to 20% (Isc/IL > 1000) and relaxing even-order limits18.
Power & Harmonic Architecture | Operating Principle | Typical Distortion Profile | Capital, Footprint & Reliability Trade-offs |
|---|---|---|---|
6-Pulse Diode VFD + Line Reactor / Passive Filter | Standard 6-diode bridge paired with 3–5% input reactor or tuned LC harmonic trap66 | Unfiltered: 35–80% THDi; line reactor: ~30–40% THDi; passive LC trap approaches IEEE 519 near rated load60 | Lowest CAPEX and simplest spare stocking; passive LC capacitors risk system resonance or dielectric stress under genset switching22 |
Multi-Pulse Transformer (12-, 18-, 24-Pulse) | Phase-shifting transformer feeds multiple bridges (30° for 12-pulse, 20° for 18-pulse, 15° for 24-pulse)22 | 24-pulse cancels 5th, 7th, 11th, 13th, 17th, 19th66; high-order harmonics (>21st/23rd) still caused 24.1–25.3% THDv in a 600 V offshore case22 | Heavy, bulky dry-type VPI transformers with long manufacturing lead times; cancellation degrades under light load or voltage unbalance67 |
Active Front-End (AFE) VFD | Bi-directional IGBT PWM rectifier actively controls sinusoidal input current at unity power factor22 | Typically 2–5% THDi below 50th harmonic67; carrier switching ripple above 50th yielded 3.25% THDv (>50th) in an offshore measurement22 | Eliminates phase-shifting transformers and enables 4-quadrant regeneration22; costs ~1.4–1.7× standard VFDs per an AHF vendor estimate71; boosts DC bus voltage (often needing dV/dt motor filters)23 |
Centralized Active Harmonic Filter (AHF) | Parallel power-electronic converter injects inverse harmonic canceling currents onto a shared AC bus67 | Dynamically compensates harmonic currents across connected VFDs and auxiliary loads toward ~5% TDD67 | Lower cabinet footprint and CAPEX when serving multi-drive buses; fails gracefully without tripping connected propulsion drives71 |
Common DC Bus (Onboard DC Grid) | Central 1,000 VDC distribution feeds motor inverters directly from shared DC busbars1 | ABB documentation reports AC switchboard rectifier THD is eliminated on DC propulsion distribution1 | Supports variable-speed gensets and direct battery connection; requires DC-specific semiconductor/fuse protection1 |
2. Marine Battery Systems (ESS) & Hybrid Modes
Commercial marine Energy Storage Systems predominantly deploy Lithium Nickel Manganese Cobalt Oxide (NMC) or Lithium Iron Phosphate (LFP) cells45. NMC cathodes operate at 3.6–3.7 V nominal and achieve high cell-level specific energy (150–250+ Wh/kg, up to 250–300 Wh/kg in high-nickel variants), stronger cold-temperature discharge performance, and high fast-charge acceptance72. LFP cells operate at 3.2 V nominal without cobalt or nickel, yielding ~20–40% lower cell energy density (90–160 Wh/kg, advancing toward ~200 Wh/kg in next-generation formulations; IEA 2025 pack data cited in industry tutorials places LFP packs roughly one-fifth lower by mass and one-third lower by volume than NMC)72. However, LFP's stable olivine structure tolerates routine 100% SoC cycling (whereas NMC is frequently capped near ~80% for longevity), delivers 2–4× longer cycle life (3,000–6,000 cycles in marine/boat duty and up to 10,000 cycles in stationary BESS, versus 1,000–3,000 for NMC to 80% State of Health), and lowers cell cost by roughly 30% (~$80–100/kWh for LFP vs. ~$100–150/kWh for NMC in 2025–2026 commercial estimates)72. Vendor thermal aging data also indicates that at 45 °C ambient, NMC cycle life degrades 40–50% faster than rated specs compared to 20–30% for LFP74.
Once packaged to meet maritime thermal-runaway anti-propagation rules, volumetric and weight gaps between chemistries can narrow or invert. NMC enters thermal runaway at ~150–210 °C and releases structural oxygen during cathode decomposition, liberating roughly three times the thermal energy of LFP alongside toxic hydrogen fluoride (HF), CO, and metal vapors—necessitating substantial cell spacing and containment shields77. Consequently, Corvus Energy's flagship high-rate NMC Orca ESS (5.6 kWh / 50 VDC modules, up to 3C continuous) delivers 77 Wh/kg and 88 Wh/l at the pack level, whereas Corvus's rack-free lightweight NMC Dolphin NxtGen Energy string reaches 168 Wh/kg and 212.5 Wh/l (1.0C 10-second peak; sister Dolphin Power handles 2.2C continuous / 4.4C 10-second peak discharge)73. By contrast, LFP's covalent P–O bonds raise thermal runaway onset to ~270–300 °C with minimal oxygen release78. Exploiting this intrinsic stability, Corvus Energy's LFP Blue Whale ESS (48.23 kWh / 80 VDC modules, 0.7C continuous / 1C 20-minute peak) achieves 122 Wh/kg at the module level while cutting total battery-room weight by ~30% and volume by ~50% compared to Orca—with newer high-rate LFP systems (Blue Whale NxtGen Power, built on BYD cell technology) extending LFP into high-C-rate tug and workboat duty45.
Chemistry / Marine ESS System | Nominal Voltage & Energy Density | C-Rate & Cycle Life | Thermal Runaway & Safety Profile | Primary Marine Application Fit |
|---|---|---|---|---|
NMC Cell Baseline | 3.6–3.7 V; 150–300 Wh/kg (cell)74 | 1,000–3,000 cycles (80% SoH); 40–50% faster fade at 45 °C (vendor data)74 | Onset ~150–210 °C; cathode liberates O2; faster fire cascade and toxic HF release79 | Weight/space-limited fast ferries, cold-climate craft, high-power peaking72 |
LFP Cell Baseline | 3.2 V; 90–160 Wh/kg (next-gen ~200 Wh/kg)72 | 3,000–6,000+ cycles (up to 10,000 stationary); 20–30% fade at 45 °C (vendor data)72 | Onset ~270–300 °C; minimal O2 release; ~1/3 runaway energy of NMC77 | High-cycle ferries, OSV spinning reserve, bulk zero-emission ESS45 |
Corvus Orca ESS (NMC) | 350–1,200 VDC pack; 77 Wh/kg & 88 Wh/l (pack)73 | Up to 3C continuous charge/discharge73 | Passive single-cell thermal runaway isolation + exhaust gas system73 | OSVs, tugs, active-heave cranes needing high continuous C-rates73 |
Corvus Dolphin NxtGen Energy / Power (NMC) | Up to 1,205 VDC (Energy); 168 Wh/kg & 212.5 Wh/l (Energy string)81 | Energy: 1.0C 10-s peak; Power: 2.2C cont. / 4.4C 10-s peak discharge80 | Rack-free modular architecture with passive single-cell TR isolation80 | Weight-sensitive yachts, high-speed passenger vessels, rapid turnarounds80 |
Corvus Blue Whale ESS (LFP) | 560–1,120 VDC pack; 122 Wh/kg (module); ~30% lighter / ~50% smaller room vs. Orca45 | 0.7C continuous; 1C peak (20 min)45 | Passive cell-level anti-propagation + off-gas exhaust ducting45 | Large zero-emission coastal vessels, cruise liners, cargo ships45 |
A hierarchical Battery Management System (BMS) monitors individual cell voltages and temperatures, estimates State of Charge (SoC) and State of Health (SoH), enforces hardware over-voltage/over-temperature disconnect circuits and fuses, and communicates dynamic charge/discharge limits to the vessel PMS7. Because LFP exhibits an extremely flat open-circuit voltage curve across mid-SoC ranges, voltage-based SoC and dQ/dV diagnostics require tighter current integration and calibration than NMC75. High-duty marine racks commonly employ liquid cooling alongside air cooling to keep cells well below ~57 °C where Solid Electrolyte Interphase (SEI) layers begin thermal breakdown83. Crucially, maritime Hazard Identification (HAZID) analyses of past incidents found that short circuits triggered by coolant leakage and water ingress represent the leading cause of onboard thermal runaway86.
During thermal runaway, internal cell temperatures exceed 1,000 °C and cells expel roughly 2–3 liters of flammable, toxic Thermal Runaway Effluent Gas (TREG) per Ah of capacity87. DNV-GL full-scale battery fire testing demonstrated that CO is the primary sustained early-stage indicator gas and that early-stage vent gas is cold and heavier than air, pooling along the deck before later heating and rising—requiring dual-elevation gas detectors at both floor and ceiling levels plus breathing-zone sensors (1–1.8 m) for CO, NO2, and HCl IDLH hazards89. Following shipboard events such as the Brim ferry incident, DNV's July 2023 ventilation rules and NMA draft regulations (for Li-ion systems ≥20 kWh) require gastight enclosures (door leakage ≤0.5 m³/m²·h at 50 Pa), auto-activated CCTV, emergency-backed dual gas detectors, automatic shutdown of ventilation and non-explosion-proof gear on gas/smoke detection, and pressure-relief off-gas ducts terminating ≥3.0 m clear of intakes and muster stations34. Crucially, independent fire-suppression tests confirm that clean-agent flooding (Novec 1230, FM-200, CO2) extinguishes open flames without electrical shorting91 but cannot arrest internal exothermic runaway or stop re-ignition92. Breaking the self-sustaining thermal feedback loop requires cooling cells below onset temperature via high-pressure water mist or fixed fresh-water spray (NMA draft rules specify 5 L/min/m² continuous flow for 60 minutes alongside inert gas)34, although DNV testing and NMA guidance warn that poorly managed ventilation or water sprays can displace gases into explosive pockets unless structural and ventilation controls are integrated89.
Marine hybrid systems operate across four primary modes11. In Peak Shaving and Strategic Loading, the ESS injects power during wave-slam, winch, or DP thruster transients and recharges during load dips, holding diesel or slower-responding LNG dual-fuel engines near their 60–85% SFOC sweet spot11; academic optimization studies confirm maximum fuel savings arise when batteries allow entire generators to be shut down rather than run lightly loaded94. In Spinning Reserve, online batteries replace an idling backup diesel generator during DP operations while reserving a protected SoC buffer—never assuming 100% pre-fault charge or 0% cutoff—sufficient to guarantee safe operation termination after a generator trip11. While vendor estimates (Wärtsilä, Danfoss, GLO Marine) typically project 10–30% fuel savings and up to 50% longer maintenance intervals3, verified operational data reported by Eidesvik Offshore (Karlsen & Eriksen, MTS DP Conference 2018) grounds real-world returns: the Viking Energy (652 kWh / 1,600 kW ESS, the first vessel certified for battery spinning reserve in DP) achieved 27.0% fuel savings in DP mode, 7.6% in transit, 21.5% in port/standby, 17% overall fuel reduction, and a 36% cut in genset running hours, while sister OSVs Viking Princess (511 kWh / 1,600 kW) and Viking Queen achieved 15% and 10–12% overall fuel savings respectively11. In Zero-Emission Transit, vessels disconnect all engines for silent harbor or protected-zone operation8; Norway's NMA rules prohibit direct CO2 and CH4 exhaust emissions in five UNESCO World Heritage fjords (Geirangerfjorden, Sunnylvsfjorden, Tafjorden, Nærøyfjorden, Aurlandsfjorden) effective 1 January 2026 for passenger ships <10,000 GT and 1 January 2032 for ships ≥10,000 GT, requiring mandatory shore-power use at equipped berths (with certified biogas allowed conditionally at 50–65% GHG reduction and RFNBOs at ≥70% reduction plus N2O abatement)14. Finally, Energy Harvesting captures regenerative power from lowering active-heave cranes or decelerating propellers back into the battery bank13.
3. Azimuth Thrusters & Podded Propulsion (Azipod)
Azimuth propulsion integrates thrust and 360° steering into a single outboard rotating unit, eliminating conventional rudders and long inboard shaftlines6. Architectures separate into mechanically geared azimuth thrusters driven by inboard prime movers and gearless electric podded drives enclosing the motor directly within the submerged pod98.
Among mechanical units spanning ~55 kW to 8 MW100, Z-drive thrusters accept a horizontal input shaft from an inboard diesel engine or electric motor, routing torque through an upper 90° bevel gearbox, a vertical intermediate shaft inside the slewing column, and a lower 90° bevel gearbox to the propeller98. Z-drives minimize vertical hull height and allow engine-driven hydraulic/lube pumps15, but dual right-angle gear sets and bearings impose ~4% to 5% mechanical transmission losses30. L-drive thrusters mount an electric (or hydraulic) drive motor vertically atop the steering stem, eliminating the upper bevel mesh and reducing mechanical transmission losses to ~2% to 3% with a more horizontally compact footprint, at the cost of tall overhead hull clearance restricted mainly to deeper machinery spaces or offshore structures15. Both mechanical types support fixed-pitch (FPP) or controllable-pitch (CPP) propellers, retractable combi-tunnel wells, and diver-exchangeable underwater-mountable assemblies25.
Gearless podded drives—introduced commercially by ABB's Azipod in 1990—mount a fixed-pitch propeller directly onto the rotor shaft of a submerged three-phase electric motor inside a streamlined steel pod, eliminating bevel gears entirely5. Motor topology splits decisively by unit power. In the 1–4.5 MW range (e.g., Azipod C/CO open-water units and Azipod CZ drilling thrusters rated up to 84 metric tons static thrust), pods typically use Permanent Magnet Synchronous Motors (PMSMs)33 (though Compact Azipod also offers hybrid-cooled asynchronous induction options109). Because permanent magnets provide rotor excitation without induced rotor current, PMSMs eliminate induction-motor slip losses (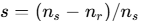 , where
 is rotor speed), reach ~98% electrical efficiency, deliver strong low-speed maneuvering torque, and permit a slimmer pod diameter that cuts hydrodynamic frontal drag52. Compact C/CO/CZ pods reject heat passively via natural convection through the steel pod shell directly to surrounding seawater, eliminating auxiliary cooling fans and water ducts17. Above 5–6 MW—spanning Azipod V/VI (3–13 MW, ice-class pods 2–17 MW) and Azipod X/XO2100 (10–21/22 MW, with XO2100 rated at 13–18 MW at 122–170 rpm and ~3,000 V F/F insulation)—engineering literature shows wound-rotor / brushless Synchronous Motors (SM) dominate (alongside asynchronous motors in select ~5 MW ice designs) because rare-earth magnet supply costs, confined rotor heat dissipation, and thermal/short-circuit demagnetization risks constrain large PMSMs5. High-power pods require active closed-loop forced air cooling; an Azipod XO2100 uses a Cooling Air Unit (CAU) with dual 55/63 kW radial fans and double-tube fresh-water heat exchangers consuming 100 m³/h of 36 °C LT cooling water (6 bar), plus separate LT water cooling for drive-end (13 kW loss) and non-drive-end (30 kW loss) bearings26.
Continuous 360° pod slewing relies on a heavy Slip Ring Unit (SRU) (4,000 kg on an XO2100) transferring megawatt-class propulsion power and auxiliary circuits across sliding brush-ring contacts26, while rotating marine and wind assemblies increasingly incorporate Fiber-Optic Rotary Joints (FORJs) for EMI-immune, wear-free optical data transmission (though the reviewed XO2100 product introduction document does not explicitly mention fiber-optic hardware)26. Steering torque is provided by multiple redundant inverter-driven electric motors—two 400 kg Steering Drive Units giving a 12°/s slew rate on Azipod CO (with single-drive fallback at lower torque), scaling to four 75–90 kW asynchronous motors (360 kg drive/braking-resistor cabinets each) turning planetary reduction gears with torque-overload clutches, fail-safe spring-shut brakes, and hot-standby dual Electric Steering Control Units (ESCU) on XO2100 units17. Critically, independent naval architectural analysis by Lateral Naval Architects (2024) comparing six pod installations against an optimized shaftline shows pod efficiency depends heavily on hull-propulsor Quasi-Propulsive Coefficient (QPC) matching: poor-QPC pods demanded 0–6% more delivered power (8–17% more brake power), whereas high-QPC pods achieved 8–14% lower delivered power (nearly matching shaftline brake power)99, while ABB estimates up to 20% overall vessel energy savings when combining gearless transmission with pulling hydrodynamics, larger propeller diameters, and sleeker aft hull lines6.
Propulsion Type | Drivetrain & Motor Location | Transmission & Cooling Losses | Power Range & Propeller Options | Slewing & Space Integration |
|---|---|---|---|---|
Z-Drive Azimuth Thruster | Inboard horizontal diesel or E-motor; 2× 90° bevel gears + vertical shaft98 | ~4–5% gear/shaft mechanical losses30 | ~55 kW–8 MW; open or ducted, FPP or CPP35 | Vertically compact inside hull; hydraulic or electric steering15 |
L-Drive Azimuth Thruster | Inboard vertical E-motor; 1× lower 90° bevel gear103 | ~2–3% gear/shaft mechanical losses30 | Up to ~8 MW; electric/hydraulic drive only; open or ducted30 | Horizontally compact, tall vertical hull space required15; electric steering standard on E-units102 |
Gearless PMSM Pod (e.g., Azipod C / CO / CZ) | Submerged PMSM directly on FPP shaft; zero gears32 | Zero gear loss; ~98% motor efficiency; slim pod hub106 | ~1–4.5 MW (CZ up to 84 t static thrust); pulling (CO) or 7°-tilted pushing nozzle (CZ)33 | Direct seawater convection cooling (no CAU ducts); ~12°/s electric steering + SRU17 |
Gearless Synchronous Pod (e.g., Azipod V / X / XO) | Submerged brushless/wound SM directly on FPP shaft; zero gears5 | Zero gear loss; CAU forced air (2× 55–63 kW fans) + LT water cooling losses26 | 3–22 MW (ice 2–17 MW); pulling FPP or CRP-aft configuration6 | 4,000 kg SRU + 4× 75–90 kW steering drives + fail-safe spring brakes + hot-standby ESCU26 |
4. Hydrodynamics & Thrust Vectoring
Selecting a pulling (tractor) versus pushing propeller depends primarily on the vessel's thrust load coefficient ( )30. In pulling mode, the propeller sits forward of the strut and pod housing, drawing uniform, unobstructed inflow6. Model tests and analysis by Dang (Wärtsilä Lips, MTS DP Conference 2004) show that pushing thrusters operating at low thrust loading (
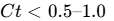 , typical of fast passenger and transit vessels) lose 30% to 40% of propulsor thrust to parasitic drag on the strut, underwater gearcase, and stabilizing fin immersed in the high-speed propeller slipstream30. Pushing blades also require larger blade area ratios to suppress cavitation behind the strut, penalizing open-water efficiency30, whereas clean-inflow pulling pods lower hull pressure pulses and Underwater Radiated Noise (supporting notations like DNV Silent-E)106 and enable Double-Acting Ship (DAS) icebreakers to steam astern through heavy ridges while keeping a streamlined open-water bow6. Conversely, at high thrust loadings (
 , typical of heavy DP station-keeping and bollard pull), pushing thrusters outperform pulling units and limit housing/strut losses to roughly ~5% of propulsor thrust30. For Contra-Rotating Propellers (CRPs), standalone double-screw azimuth thrusters favor pushing mode because a pulling strut inside the dual-propeller wake creates excessive drag30, whereas hybrid CRP-Azipod layouts (a pulling pod behind a conventional shaftline screw) recover swirl losses for >10% efficiency gains on fast ferries such as Akashia and Hamanasu109.
When static bollard pull or low-speed DP thrust dominates, propellers are enclosed in accelerating Kort nozzles (such as the Wageningen 19A profile or high-efficiency LIPS HR and Brunvoll ICP profiles)25. At zero advance speed ( ), the nozzle suppresses tip vortices and generates an airfoil circulation force that raises low-speed thrust by up to ~30% over an equivalent open propeller25. While idealized zero-speed nozzles approach a 50:50 propeller-to-nozzle thrust split, CFD and waterproof dynamometer measurements by Funeno (Kawasaki, 2009) demonstrate that gearcase housing blockage (
 ) strongly alters nozzle inflow and can shift the thrust ratio toward ~80:20121. Nozzle merit coefficients (
 ) exceed open propellers (~0.9 max at low pitch) and CRPs (1.0–1.1), sustaining high bollard efficiency even at compact high pitch provided pitch ratio (
 ) stays above stall drop-off limits (
 for 19A;
 for LIPS HR)30. Because 19A nozzles suffer high-speed drag penalties once
 falls below 1.5 (and trail CRPs below
 ), thin-foil high-efficiency nozzles (LIPS HR) offer 8–10% higher open-water efficiency than 19A nozzles and outperform open propellers down to
 (and CRPs above
 )30.
During multi-directional maneuvering, thruster-hull and thruster-thruster interactions degrade net thrust substantially30. Under the Coanda effect, an angled thruster jet attaches to curved hull plating, skegs, or semi-submersible pontoons, inducing low-pressure suction and frictional drag that opposes thrust—losses measured via CFD and basin tests at up to 46% of net thrust on semi-submersibles122. Tilting the entire submerged propulsion module downward by 7 degrees (as on Azipod CZ rig thrusters) directs wake wash clear of neighboring pontoons, delivering a 20–30% net thrust advantage over non-tilted thrusters across critical azimuth sectors (and 4–6% over tilting only the nozzle)33. Meanwhile, pointing one thruster's slipstream into a downstream unit elevates the downstream advance ratio and starves its thrust122; DP thrust allocators solve 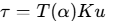 (mapping commanded surge, sway, and yaw forces
 to thruster angles
 and outputs
 ) while enforcing static or speed-ratio-dependent dynamic forbidden/spoil sectors around adjacent thrusters and skegs27. Operators must also manage thruster biasing carefully so minimum-thrust deadbands are avoided without violating approved DP redundancy rules128. Unlike fixed transverse tunnel thrusters—which lose 25–35% inlet suction efficiency and suffer severe jet deflection above 4–5 knots ship speed—retractable and stern azimuth thrusters maintain directional authority across transit speeds129. In harbor operations, full 360° vectoring permits pure lateral crabbing and zero-speed pivoting15, though placement shapes capability: Azimuth Tractor Drive tugs (bow-mounted units) yield an almost symmetrical 360° thrust polar diagram, whereas Azimuth Stern Drive (ASD) tugs experience pronounced lateral thrust loss due to skeg wake and transverse hull drag130.
5. Failure Modes & Diagnostics
Marine VFD Insulated Gate Bipolar Transistor (IGBT) failures stem from early manufacturing flaws, sudden electrical/thermal overstress, or progressive wear-out132. Overstress failures follow gate or collector-emitter voltage spikes caused by high turn-off  , stray bus inductance, unabsorbed motor regenerative braking overvoltage, saturation-voltage (
 ) mismatch across paralleled IGBTs, coolant/fan loss, or conductive salt-mist contamination causing gate-driver flashovers132. Long-term wear-out arises from thermomechanical fatigue across mismatched material expansion coefficients—driving bond-wire lift-off and solder fatigue beneath the silicon die and direct-bonded copper substrate—alongside Time-Dependent Dielectric Breakdown (TDDB) of gate oxides132. An IMCA DP incident case study (DPE 04/23) illustrates diagnostic hazards: after a port azimuth VFD tripped three times on a DC over-voltage alarm, crew verified green control-board LEDs and repeatedly reset the drive; the fourth restart caused the damaged IGBT module to trigger generator protection on DG 2, blacking out the port switchboard and tripping Bow Thruster 1 and Azimuth Thruster 3 (station-keeping survived on the remaining redundant group)137. Recurring DC-bus faults require isolation and power-stage diagnostics rather than blind resets. High-frequency VFD PWM switching also induces common-mode shaft voltages that discharge across lubricating films in bearings and mechanical seals via electrostatic discharge (ESD), creating discrete pitting craters, dark halos, and eventual leakage139. Field diagnosis follows LOTO isolation, a 5–10 minute wait for DC-bus capacitor discharge, and dynamic shaft-probe testing across 30/45/60 Hz: installing a shaft grounding ring (SGR) must hold peak shaft voltage below 5 V; if peaks exceed 20 V, output dV/dt or sinewave filters are required139.
On azimuth mechanical and steering assemblies, propeller shaft seals and steering tube seals represent the highest-frequency replacement parts35. Water ingress past worn or net-fouled seals produces emulsified lower gear oil, requiring bearing inspection rather than seal-only swaps, while outward leaks risk oil-to-sea pollution35. Trending lube-oil ferrous debris distinguishes gradual gear/bearing wear from abrupt step spikes caused by grounding, ice impact, or rope strikes, and heading-dependent vibration isolates slewing-ring bearing wear from rotating driveline faults35. Steering anomalies—sluggish response or port/starboard lag—point to hydraulic pressure loss, fouled filters, failing proportional valves, or electric steering converter faults, whereas a slipped steering encoder or feedback transmitter introduces dangerous thrust-vector errors between bridge indication and physical pod heading during DP35. Underwater-mountable housings and port-replaceable shaft seals (as on Azipod XO2100 units) minimize unscheduled drydocking26.
In podded Slip Ring Units (SRUs), continuous brush-ring friction causes typical carbon brush wear of 0.2–2 mm per million revolutions across a 5–50 million revolution design life, accelerating with rotational velocity, excessive spring tension, elevated housing heat, and humidity141. Diagnostics track brush length against minimum limits starting at 50% predicted life, trend contact resistance with a milliohmmeter, and inspect for loss of the uniform dark carbon film (pitting, grooving, or bright bare metal)141. Maintenance cleans housings strictly with lint-free wipes and isopropyl alcohol (never compressed air, which blows conductive carbon dust onto adjacent insulation), followed by a staged brush run-in (30 minutes each at 20%, 50%, and 100% speed)141. Hybrid SRU packages isolate sensitive signals onto non-contact FORJs to eliminate brush noise on control buses117.
Lithium-Ion cells degrade through three coupled mechanisms: Loss of Lithium Inventory (LLI), Loss of Active Material (LAM), and impedance rise144. Continued SEI layer growth—driven by electrolyte reduction below 1 V vs. Li/Li+—thickens over time ( ), accelerating exponentially with temperature and high SoC while permanently trapping lithium and blocking ion transport85. Lithium plating occurs when cold temperatures or high charge C-rates near full SoC push anode potential below 0 V vs. Li/Li+, depositing metallic lithium that forms dead lithium and separator-threatening dendrites85. Repeated lithiation volume swings (~10% in graphite, ~300% in silicon additives) fracture active particles—exposing fresh graphite to secondary SEI growth—while dissolved cathode transition metals (notably manganese) migrate to catalyze anode electrolyte decomposition144. Because marine AC main buses and 1,000 VDC battery/VFD links operate as unearthed IT (Isolated Terra) systems, a single earth fault draws negligible capacitive current and permits uninterrupted operation—but leaves the vessel vulnerable to a destructive phase-to-phase or rail-to-rail short circuit upon a second fault147. Continuous Insulation Monitoring Devices (IMDs, such as Bender ISOMETER® units) inject active measuring signals capable of reading kΩ–GΩ insulation resistance while automatically adapting to high system leakage capacitances (up to 100 µF on VFD-filtered DC energy storage networks)36; paired online fault locators (e.g., ISOSCAN® EDS) trace test pulses via feeder CTs to isolate faulted circuits while live, and bus-tie decoupling logic (e.g., ISONET) prevents multiple IMDs from interfering when closed bus-ties link redundancy zones149.
Blackouts commonly follow fuel-filter clogging, fuel-injector or valve defects, governor or AVR exciter-diode failures, un-shed generator overloads, or cascading VFD short-circuit trips42. Class rules mandate at least two independent blackout-start stored-energy sources (starting air or batteries, sized for three start attempts per engine) feeding separated switchboard busbar sections43. Under standard SOLAS and class automation, recovery proceeds sequentially:
- Blackout Detection & Isolation (0–5 s): Undervoltage/underfrequency trips disconnect main generator breakers and trigger PMS load shedding; bridge watchkeepers zero engine telegraphs and display Not Under Command (NUC) lights/shapes if sustained, while engineers acknowledge—without resetting—alarms to preserve fault diagnostics43.
- Standby & Emergency Restoration (≤45 s): The PMS auto-starts the designated standby diesel generator (typically cranking in ~4–15 s and closing onto the main switchboard around ~18 s)155. If the standby fails (Dead Ship), the Emergency Generator auto-starts (~4–9 s), isolates the MSB–ESB tie breaker, and energizes the Emergency Switchboard within the mandatory 45-second SOLAS/ABS/DNV limit (~19–22 s in documented ship procedures) to supply emergency steering unit No. 1, navigation, and battery safety systems42.
- Sequential Auxiliary & Propulsion Restart: Once main busbar voltage and frequency stabilize, automated sequential-restart timers bring critical lube-oil, jacket-water, seawater cooling, and steering hydraulic pumps back online in staggered steps to avoid simultaneous inrush re-tripping, followed by VFD pre-charging, thruster restoration, and return of bridge propulsion control155.
- Hybrid ESS Ride-Through & Black Start: On battery-hybrid and DC-grid ships, an online ESS configured for spinning reserve/UPS reacts instantaneously—bridging transient generator loss before the 15–45 s diesel start window expires—or supplies immediate black-start power to restart auxiliary pumps without relying solely on starting-air compressors7.
References
- — 5.7 Onboard DC GridTM - ABB, https://library.e.abb.com/public/8a79a50eed6e4cf1ac673988bd448b32/Detailed%20Description%20_%20Onboard%20DC%20Grid.pdf
- Onboard DC Grid - ABB, https://library.e.abb.com/public/b4f3f099e9d21360c1257a8a003beac2/ABB+Generations_20+Onboard+DC+grid.pdf?x-sign=PdxeYFKFIJ5RHJf4xio692D5CSea63ZLKMpU0A%2FN9P7WNc4J9t97JGgJjS59umM6
- Hybrid power & battery systems for offshore vessels - GLO Marine, https://glo-marine.com/news/hybrid-power-and-battery-systems-for-offshore-vessels
- AC/DC Marine power management system (PMS) - ComAp, https://www.comap-control.com/application-areas/marine/ac-dc-power-management/
- Advancements in Electrical Marine Propulsion Technologies, https://scielo.org.za/pdf/arj/v116n1/02.pdf
- Azipod® electric propulsion Marine and Ports - ABB, https://www.abb.com/global/en/industries/marine/solutions/marine-electric-propulsion/azipod
- Marine Hybrid Power Systems Explained | TURNER ECS, https://turner-ecs.com/new-projects-marine-offshore/marine-hybrid-power-systems/
- 7 fascinating hybrid ship trends everyone needs to know - Wärtsilä, https://www.wartsila.com/insights/article/seven-fascinating-hybrid-ship-trends-that-everyone-needs-to-know-about
- Hybrid Power | Ulstein Group, https://ulstein.com/system-integration/power-solutions/hybrid-power
- The step forward Onboard DC Grid - ABB, https://new.abb.com/docs/librariesprovider91/articles/lm00614-onboard-dc-grid-brochure_june2014_1.pdf
- Batteries as power sources in DP systems, https://dynamic-positioning.com/proceedings/dp2018/03.1%202018%20DP%20Conference%20Power%20and%20Design%20Aleks%20Karlsen%20and%20Sverre%20Eriksen.pdf
- Promoting more robust DP power systems with closed bus-ties - DNV, https://www.dnv.com/expert-story/maritime-impact/promoting-more-robust-DP-power-systems-with-closed-bus-ties/
- Peak shaving and other ways to use batteries on a vessel - Echandia, https://www.echandia.com/en/news/articles/peak-shaving-and-other-ways-to-use-batteries-on-a-vessel
- Zero-emission requirements for the World Heritage fjords adopted, https://www.sdir.no/en/news/zero-emission-requirement-for-the-world-heritage-fjords-adopted/
- Azimuth Thruster 360° Marine Propulsion, https://www.bergpropulsion.com/azimuth-thruster/
- How does a marine hybrid power system optimize fuel efficiency?, https://www.cm-energy.com/knowledge/how-does-a-marine-hybrid-power-system-optimize-fuel-efficiency
- Azipod® CO Product Introduction | ABB, https://library.e.abb.com/public/933fa7cfa4392993c1257b1a005b78e9/Azipod%20CO_Product%20Introduction.pdf
- Hazards of Harmonic Distortion in Marine Systems | PDF - Scribd, https://www.scribd.com/document/680191345/MGN-449
- Ship Shore Power & Cold Ironing Connection Guide, https://marineinspection.app/article/ship-shore-power-cold-ironing-connection-compliance-guide
- IEC 80005 Standard Series - ICCE, https://icce.com/2025/05/21/the-iec-80005-standard-series/
- IEC/IEEE 80005-1 for Ship-Side Shore Power - Orion Marine, https://www.orionnmar.com/blog/iec-ieee-80005-1-ship-side-shore-power
- Meeting Harmonic Limits on Marine Vessels, https://www.harmonicsolutions-oilandgas.com/wp-content/uploads/2014/08/IEEE-ESTS07-Meeting-Harmonic-Limits-on-Marine-Vessels.pdf
- Active Harmonic Filters vs. Active Front Ends, https://americas.hammondpowersolutions.com/resources/whitepapers-and-technical-articles/ahf-vs-afe
- 24-Pulse Phase Shift Transformer Overview | PDF - Scribd, https://www.scribd.com/document/782061111/24-Pulses-Phase-Shift-Transformers
- PROPULSION, POSITIONING & MANOEUVRING SYSTEMS - MTSI, https://mtsi.cl/documentos/SistemasPropulsionBrunvoll.pdf
- Azipod® XO2100 Product Introduction | ABB, https://library.e.abb.com/public/dc7fe424f9f91cadc1257b1a005b78bf/Azipod_XO2100_Product%20Introduction.pdf
- Optimal Thrust Allocation Methods for Dynamic Positioning of Ships, https://repository.tudelft.nl/file/File_ba9680a1-a99e-4c46-ab97-f6cd184352cf
- Analysis of Thruster Faults and a Fault-Tolerant Sliding Mode ... - MDPI, https://www.mdpi.com/2075-1702/14/11/1316/pdf
- Thruster - SVA Potsdam, https://www.sva-potsdam.de/en/rudder-propeller/
- Hydrodynamic Aspects of Steerable Thrusters, https://dynamic-positioning.com/proceedings/dp2004/thrusters_dang.pdf
- ACTIVE FRONT END (AFE) - Kongsberg, https://www.kongsberg.com/contentassets/5e14e43b955c48358d27799c4c9e6749/12.propsyst_2p_10.09.13.pdf
- Azipod® Propulsion - ABB, https://search.abb.com/library/Download.aspx?DocumentID=3BNP100004D0016&LanguageCode=en&DocumentPartId=&Action=Launch
- Azipod® C Propulsion and Thruster Units for 1300 – 4500 kW - ABB, https://library.e.abb.com/public/e0da7f3b33ef0a4ac1257b1a005b7907/Azipod%20C%20%20Basic.pdf
- Draft Regulations on ships using battery systems with lithium-ion, https://www.sdir.no/contentassets/532d23781c56481a9feb6af2d07809f8/appendix-2.-proposal-for-regulations-english-translation.pdf
- Azimuth Thruster Parts — Z-Drive & L-Drive Spares - Exakt Propulsion, https://marinepropulsionparts.com/spare-parts/propulsion-parts/azimuth-thrusters
- Insulation monitoring - bender-de.com, https://www.bender.de/en/products/insulation-monitoring/
- Free Article: System redundancy on cruise ships and DP vessels, https://www.nautinst.org/resources-page/system-redundancy-on-cruise-ships-and-dp-vessels.html
- DP2 Vessel: Requirements, Operations and Classification Explained, https://ashmitenggconsultancy.com/dp2-vessel
- DP2 vs DP3: Difference Between DP Class 2 and 3 | Project2Me, https://project2-me.com/article/dp2-or-dp3-dynamic-positioning-class-in-a-newbuild-contract
- GUIDELINES ON DYNAMIC POSITIONING SYSTEMS WITH, https://www.irclass.org/media/8196/guidelines-on-dp-system-with-closed-bus-ties_dec-2025_new.pdf
- New DNV DP notation qualifiers for closed bus-ties, https://dynamic-positioning.com/proceedings/dp2023/2023%20MTS%20DP%20Conference%202.3_KARLSEN_Paper_New%20DNV%20DP%20notation%20qualifiers%20for%20closed%20bus-ties.pdf
- BLACKOUT AWARENESS AND PREVENTION ON SHIPS, https://ww2.eagle.org/content/dam/eagle/advisories-and-debriefs/blackout-awareness-advisory.pdf
- Managing the risks of blackout | Maritime Cyprus, https://maritimecyprus.com/wp-content/uploads/2022/04/DNV-MANAGING-THE-RISKS-of-BLACKOUT.pdf
- DNV GL Handbook for Maritime and Offshore Battery Systems, https://sustainableworldports.org/wp-content/uploads/DNV-GL_2016-Handbook-maritime-offshore-battery-systems-report.pdf
- Corvus Blue Whale, https://old.corvusenergy.com/wp-content/uploads/2019/05/datasheets_Corvus-Energy_Blue-Whale-ESS_2025.02.23.pdf
- SOLAS Requirement on steering gear system - DieselShip, https://dieselship.com/marine-technical-articles/marine-engineering-knowledge-general/steering-gear/solas-requirement-on-steering-gear-system
- SOLAS Ch. II-1 Reg. 29 - Steering gear | IMORULES, https://www.imorules.com/GUID-CF547534-23B3-4162-8415-6C806370E406.html
- What are Steering Gear requirements as per SOLAS? - MarineGyaan, https://marinegyaan.com/what-are-steering-gear-requirement-as-per-solas/
- Ship Steering & Manoeuvrability (Steersafe) - EMSA, https://www.emsa.europa.eu/steersafe.html
- MSC.1/Circ.1398 10 June 2011 UNIFIED INTERPRETATION OF, https://www.register-iri.com/wp-content/uploads/MSC.1-Circ.1398.pdf
- Hybrid Propulsion - Danfoss, https://assets.danfoss.com/documents/latest/241096/BE445846409035en-000101.pdf
- Induction Motor Slip: Why PMSM Rotors Stay in Sync, https://www.leadgomotor.com/en/insights/induction-motor-slip-vs-pmsm-synchronism/
- — Onboard DC Grid – a system platform at the heart of Shipping 4.0, https://library.e.abb.com/public/7113040b09fc468d9136944a35e784fa/160-167.pdf
- Onboard DC Grid for enhanced DP operation in ships, https://dynamic-positioning.com/proceedings/dp2011/power_hansen.pdf
- Onboard DC Grid - Energy Efficiency Handbook - ABB, https://new.abb.com/marine/energy-efficiency/energy-handbook/onboard-dc-grid
- Dynamic AC (DAC) - save fuel cost Marine & Ports - ABB, https://new.abb.com/marine/systems-and-solutions/electric-solutions/dynamicac
- UNIFIED APPROACH TO VERIFICATION, VALIDATION AND ... - ocimf, https://www.ocimf.org/doclink/jdp01-unified-approach-to-the-verification-validation-and-assurance-of-dp-systems-rev1-sec/eyJ0eXAiOiJKV1QiLCJhbGciOiJIUzI1NiJ9.eyJzdWIiOiJqZHAwMS11bmlmaWVkLWFwcHJvYWNoLXRvLXRoZS12ZXJpZmljYXRpb24tdmFsaWRhdGlvbi1hbmQtYXNzdXJhbmNlLW9mLWRwLXN5c3RlbXMtcmV2MS1zZWMiLCJpYXQiOjE3NTg3MTMzOTUsImV4cCI6MTc1ODc5OTc5NX0.sEwoE1x_-hfHWe68FduLJ5b_dwaB7iK45uHOtmtib6c
- Overview of Shore Power Sockets and Plugs - IEC/IEEE 80005, https://www.sustainable-ships.org/stories/overview-shore-power-sockets-plugs-2
- VFD Harmonics & Mitigation: Complete Guide (IEEE 519) - CalcPanel, https://calcpanel.com/guides/vfd-harmonics-mitigation
- Total Harmonic Distortion (THD): IEEE 519 Limits and Causes, https://www.fabrico.io/blog/total-harmonic-distortion/
- IEEE Std 519-2014 Harmonic Limits - Mirus International, https://www.mirusinternational.com/downloads/White%20Paper%20-%20IEEE%20Std%20519-2014%20Harmonic%20Limits.pdf
- Power quality – marine standards - Comsys, https://comsys.se/en-us/our-adf-technology/power-quality-marine-standards/
- What Is Total Harmonic Distortion (THD)? Measurement and Limits, https://www.miratekelektrik.com/en/blog/what-is-total-harmonic-distortion-thd
- IEEE 519 Harmonic Limits Explained: What Your VFDs Are Doing to, https://softnitro.com/ieee-519-harmonic-limits-explained/
- IEEE 519-2022 Harmonic Limits Table: Voltage THD and TDD, https://inspector-network.com/guides/ieee-519-explained/
- How to Select Harmonic Filters for VFDs: Passive vs Active | IMD, https://industrialmonitordirect.com/blogs/knowledgebase/harmonic-filter-selection-for-variable-speed-drives-a-technical-guide
- What pulse VFD should you be using?, https://vfds.com/blog/what-pulse-vfd-should-you-be-using
- (PDF) New marine harmonic standards - ResearchGate, https://www.researchgate.net/publication/224090117_New_marine_harmonic_standards
- 24 pulse transformer-Varelen Electric, https://www.varelen.com/news/36-pulses-output-transformer-for-variable-frequency-converter.html
- Harmonic Solutions - ABB, https://search.abb.com/library/Download.aspx?DocumentID=LVD-PHPB12U-EN&LanguageCode=en&DocumentPartId=&Action=Launch
- Active Front End Drives vs. Active Harmonic Filters - Merus Power, https://meruspower.com/blog/practical-comparison-active-front-end-drives-vs-centralized-active-harmonic-filtering/
- LFP Battery vs NMC Battery: Choosing Right Battery for Your Boat, https://www.bonnenbatteries.com/lfp-battery-vs-nmc-battery-choosing-the-right-battery-for-your-electric-boat/
- Corvus Orca, https://old.corvusenergy.com/wp-content/uploads/2019/04/datasheets_Corvus-Energy_Orca-ESS_2025.02.23.pdf
- LFP Vs NMC Battery: A Technical Comparison Of Cycle Life, Safety, https://bslbatt.com/blogs/lfp-vs-nmc-lithium-battery-comparison/
- LFP vs NMC Battery Cathode: Which is Right for Your Research, https://www.canrud.com/knowledge/battery-tutorial/lfp-vs-nmc-battery-cathode-which-is-right-for-your-research-application-164
- LFP vs NMC vs LMFP vs NCA: Battery Chemistry Guide - IONETIC, https://www.ionetic.com/battery-chemistry-guide
- LFP, NMC and Sodium-ion Compared (2026) - BatteryMBA, https://www.battery.mba/resources/lfp-vs-nmc-vs-sodium-ion
- LFP vs NMC Batteries: A Deep Dive for Energy Storage Applications, https://www.bsl-battery.com/news/comparing-lfp-and-nmc-batteries-for-solar-pros-and-cons
- NMC Battery vs LFP Safety: The Complete BESS Risk Breakdown, https://sunlithenergy.com/nmc-battery-vs-lfp-safety/
- CorvusEnergy Datasheets | PDF | Energy Storage - Scribd, https://www.scribd.com/document/1004353039/CorvusEnergy-Datasheets
- Corvus Dolphin NxtGen - Energy, https://old.corvusenergy.com/wp-content/uploads/2019/04/datasheets_Corvus-Energy_Dolphin-NxtGen-ESS-Energy_2025.02.23.pdf
- Corvus Energy expands LFP portfolio with Blue Whale NxtGen Power, https://blue-c.no/corvus-energy-expands-lfp-portfolio-with-blue-whale-nxtgen-power/
- 7-Corvus-Energy-Maritime-Energy-Storage.pdf, https://www.nsrp.org/wp-content/uploads/2021/09/7-Corvus-Energy-Maritime-Energy-Storage.pdf
- Assessment of the Risks Posed by Thermal Runaway within Marine, https://www.researchgate.net/publication/386886071_Assessment_of_the_Risks_Posed_by_Thermal_Runaway_within_Marine_Li-Ion_Battery_Energy_Storage_Systems_-_Considering_Past_Incidents_Current_Guidelines_and_Future_Mitigation_Measures
- Why Lithium Batteries Lose Capacity: Plating & SEI Explained, https://www.bonnenbatteries.com/why-lithium-batteries-lose-capacity-the-real-story-behind-plating-and-sei-film/
- Assessment of the risks posed by thermal runaway within marine Li, https://eprints.whiterose.ac.uk/id/eprint/226586/1/Manuscript_black.pdf
- Lithium Battery Fire Hazards in the Maritime Environment, https://response.epa.gov/site/download.ashx?counter=445604
- Protecting Battery Storage from Thermal Runaway, https://hct-world.com/how-fire-suppression-protect-battery-storage-from-thermal-runaway/
- Technical Reference for Li-ion Battery Explosion Risk and Fire, https://gastech.com/sites/default/files/DNV-GL%20Test%20Report.pdf
- Draft Regulations on ships using battery systems with lithium-ion, https://www.sdir.no/contentassets/532d23781c56481a9feb6af2d07809f8/english-translaton-of-the-consultation-letter.pdf
- Lithium Boat Batteries: Safety Tips & Latest Technologies, https://www.bonnenbatteries.com/lithium-boat-batteries-safety-tips-latest-technologies/
- lithium-ion battery fire suppression using water mist systems, https://www.researchgate.net/publication/355215922_LITHIUM-ION_BATTERY_FIRE_SUPPRESSION_USING_WATER_MIST_SYSTEMS
- Battery Fire Safety Ventilation for Fully Electrical Vessel - Lighthouse, https://lighthouse.nu/images/Rapporter/IP8_2022_Battery_Fire_Safety_Ventilation.pdf
- Reduction of Fuel Consumption on Hybrid Marine Power Plants by, https://www.researchgate.net/publication/309475680_Reduction_of_fuel_consumption_on_hybrid_marine_power_plants_by_strategic_loading_with_energy_storage_devices
- 03/2026: Zero emission requirements in Norwegian heritage fjords, https://www.lr.org/en/knowledge/class-news/03-26/
- Geiranger Cruise Ship Ban 2026: Can You Still Visit the Fjord?, https://pierstop.com/blog/geiranger-emissions-guide-2026
- Geiranger Unesco | Zero-Emission Fjord Future - Geirangerfjord Tours, https://geirangerfjordtours.com/geiranger-cruise-emissions-zero-emission-future/
- Azimuth thruster - Wikipedia, https://en.wikipedia.org/wiki/Azimuth_thruster
- electric azimuthing propulsion in superyachts, https://www.lateral.engineering/media/stijn_media/db/94/db940754c30d80ec31a4b6990f3f80cfa936efc9/Lateral_Technical_Paper_Azimuthing_Propulsion.WJDNm.pdf
- Z and L Drive Propulsion and Thrusters Z ... - Thrustmaster of Texas, https://thrustmaster.net/wp-content/uploads/2013/12/Z-and-L-Azimuth-Thrusters-Brochure.pdf
- Azimuth Thruster | Kalkman Marine Propulsion B.V., https://kalkman-marinepropulsion.com/en/products/azimuth-thrusters/azimuth-thruster/
- L-Drive/Z-Drive - Twin Disc, https://twindisc.com/product/l-drive/
- L-Drive Azimuth Thruster - Jinbo Marine, https://www.jinbomarine.com/L-Drive-Azimuth-Thruster.html
- Electric Azimuthing Yacht L-Drives, https://marinepropulsioninternational.com/deck-mounted-propulsion-systems/electric-azimuthing-yacht-l-drives/
- Retractable Azimuth Thrusters - ZF, https://www.zf.com/products/en/marine/products_64502.html
- — 5.11 Azipod® propulsion - ABB, https://library.e.abb.com/public/bb845dbaca5b483a984410e623534fa2/Detailed%20Description%20_%20AzipodPropulsion.pdf
- Azipod® Product Platform Selection Guide - ABB, https://library.e.abb.com/public/1b13ae404001bd3ec125778a004300ac/ABB%20-%20Azipod%20Selection%20Guide.pdf
- Azipod® CO Product Introduction | ABB, https://library.e.abb.com/public/85d7a5e53e6a8e6ec12577e7002d2359/Azipod_CO_Product+Introduction_rev+C_LowRes.pdf?x-sign=5hTxXvQn%2F89MCI%2FJOLDeYiM8vn72vPAmpxkLoLRr38P69oJJDfcJ2hYO4L6qvJxC
- AZIPOD (Azimuthing Podded Drive) - Wärtsilä, https://www.wartsila.com/encyclopedia/term/azipod-(azimuthing-podded-drive)
- Permanent magnet motors | ABB, https://www.abb.com/global/en/areas/motion/motors-generators/mv-hv-motors/synchronous-motors/permanent-magnet-motors
- Key Differences Between Synchronous and Asynchronous Motors, https://us.sumitomodrive.com/en-us/news/key-differences-between-synchronous-and-asynchronous-induction-motors
- Permanent Magnet Synchronous Motor vs Asynchronous Motor, https://veikong-electric.com/permanent-magnet-synchronous-motor-vs-asynchronous-motor-how-to-choose-for-electro-hydraulic-servo-systems/
- Azipod® - The most environmental friendly propulsion system - ABB, https://library.e.abb.com/public/ecdebba6bb4b6c5cc1257a330027c69a/Azipod_General_Presentation.pdf
- Electrical systems in pod propulsion - Chalmers Publication Library, https://publications.lib.chalmers.se/records/fulltext/64477/64477.pdf
- Comparison of Interior Permanent Magnet and Synchronous ... - MDPI, https://www.mdpi.com/2227-7390/10/9/1581
- Azimuth Thruster Overview and Types | PDF | Marine Propulsion, https://es.scribd.com/document/173263668/Azimuth-Thruster
- Slip Ring Solutions Wind Energy - Schleifring.de, https://www.schleifring.de/fileadmin/08_Downloads/SCHLEIFRING_WindEnergy.pdf
- The Ultimate Guide To Electrical Slip Rings - WayDun Tech, https://customslipring.com/ultimate-guide-to-electrical-slip-ring/
- Fibre Optic Rotary Joints: Complete Guide - BGB Innovation, https://www.bgbinnovation.com/knowledge/news-and-articles/fibre-optic-rotary-joints-complete-guide
- Azipod | PDF, https://www.slideshare.net/slideshow/azipod-239975615/239975615
- Hydrodynamic Optimal Design of Ducted Azimuth Thrusters, https://www.marinepropulsors.com/proceedings/2009/TA2-3-Funeno%20-%20Hydrodynamic%20Optimal%20Design%20of%20Ducted%20Azimuth%20Thrusters.pdf
- Designation of the Boundary Conditions for Estimating the Thrust, http://www.joet.org/upload/pdf/KSOE-2022-041.pdf
- Thrust allocation with dynamic forbidden sectors in ... - ResearchGate, https://www.researchgate.net/publication/289573118_Thrust_allocation_with_dynamic_forbidden_sectors_in_dynamic_positioning_system
- Thrusters On Semi-Submersibles And The Coanda Effect, https://thrustmaster.net/semi-submersibles-coanda-effect/
- Thruster-interaction Effects on a DP Semi-submersible and a Drill Ship, https://www.marin.nl/en/publications/thruster-interaction-effects-on-a-dp-semi-submersible-and-a-drill-ship---measurement-and-analysis-of-the-thruster-wake-flow
- Tailoring thrusters to the task - Riviera Maritime Media, https://www.rivieramm.com/news-content-hub/news-content-hub/tailoring-thrusters-to-the-task-42280
- Fuel Optimal Thrust Allocation in Dynamic Positioning, https://torarnj.folk.ntnu.no/FuelOptimalThrustAllocation.pdf
- DPE 02/22: Importance of units, https://www.imca-int.com/resources/dp/dp-incidents/importance-of-units/
- Skilful Vessel Handling - NauticalCampus, https://naca.no/skilful-vessel-handling/
- GUIDELINES FOR SAFE HARBOUR TOWAGE OPERATIONS, https://eurotugowners.com/wp-content/uploads/2017/11/STP-Guidelines-First-Edition-February-2015.pdf
- Bollard pull vs manoeuvrability: balance in a harbour tug - SYM Naval, https://sym-naval.com/blog/bollard-pull-vs-manoeuvrability/
- IGBT Module Failure Mechanisms - Dynex Semiconductor, https://www.dynexsemi.com/Portals/0/PDF/DNX_AN6442.pdf?ver=4A9y8zAk3rYM4YWjKqacgA%3D%3D
- VFD Troubleshooting: Common Faults & Solutions, https://mceautomation.com/resources/vfd-troubleshooting-common-faults
- IGBT Failure in VFD | Automation & Control Engineering Forum, https://control.com/forums/threads/igbt-failure-in-vfd.27152/
- Typical IGBT Module Failures - General Driver Motor, https://www.generaldrivermotor.com/en/news-electronica-en/typical-failures-in-an-igbt-module/
- An industry-based survey of reliability in power electronic converters, https://www.researchgate.net/publication/224077494_An_industry-based_survey_of_reliability_in_power_electronic_converters
- Port side azimuth thruster shutdown and subsequent partial blackout, https://www.imca-int.com/resources/dp/dp-incidents/read-the-room-port-side-azimuth-thruster-shutdown-and-subsequent-partial-blackout-on-dp-vessel/
- Port side azimuth thruster shutdown and subsequent partial blackout, https://www.imca-int.com/resources/dp/dp-incidents/read-the-room-port-side-azimuth-thruster-shutdown-and-subsequent-partial-blackout-on-dp-vessel/?pdf
- Troubleshoot ESD Mechanical Seal Failure on VFD Pumps, https://industrialmonitordirect.com/blogs/knowledgebase/resolving-esd-failure-of-mechanical-seals-on-vfd-driven-pumps
- Electrical Pitting in Bearings: Causes & Prevention | TFL, https://www.insulated-bearings.com/blog/bearing-electrical-erosion-causes/
- Carbon Brush Replacement Intervals and Service Procedures, https://torquety.com/crossing-the-gap/slip-ring-maintenance-carbon-brush-replacement/
- Dealing with Slip Ring Wear and Tear: A Comprehensive Guide, https://grandslipring.com/slip-ring-wear-and-tea/
- SIGNAL & POWER SLIP RINGS - Mersen, https://us.mersen.com/sites/default/files/files_imported/ptt-signal-and-power-transfer-systems-mersen-en-2107.pdf
- Lithium-Ion Battery Degradation Mechanisms - BatteryMBA, https://www.battery.mba/resources/battery-degradation-mechanisms
- Lithium ion battery degradation: what you need to know, https://www.researchgate.net/publication/350281602_Lithium_ion_battery_degradation_what_you_need_to_know
- Lithium-ion battery degradation: how to model it - arXiv, https://arxiv.org/html/2112.02037v2
- Bender Insulation Monitoring II - Electromagnetic Interference - Scribd, https://www.scribd.com/document/330725844/Bender-Insulation-Monitoring-II
- Technical aspects IT systems - Fournais-Bender, https://fournais-bender.dk/storage/TechnAspects-IT-systems.pdf
- 800V DC Data Center Insulation Monitoring - Bender Inc., https://www.benderinc.com/blog/post/electrical-risk-in-ai-data-centers-insulation-monitoring-and-fault-location-in-ungrounded-800v-dc-systems/
- ISOMETER® isoES425 - Bender GmbH & Co. KG, https://www.bender.de/en/products/insulation-monitoring/isometer-isoes425/
- Insulation monitoring: The concept - Bender UK, https://www.bender-uk.com/know-how/technology/it-system/insulation-monitoring/
- What Is Insulation Monitoring? IMD Guide | Bender Turkey Distributor, https://adeoteknik.com/en/izolasyon-izleme-imd-nedir.html
- Maritime systems - bender-de.com, https://www.bender.de/fileadmin/content/Products/b/e/Maritime-Systems_B_en.pdf
- Blackout Prevention and Recovery - Dynamic Positioning Committee, https://dynamic-positioning.com/proceedings/dp2009/risk_adnanes_pp.pdf
- Blackout Recovery Procedure for MV Mosel N | PDF - Scribd, https://www.scribd.com/document/891739907/Black-Out-Recovery
- Blackout Recovery Procedures for Ships | PDF | Pump - Scribd, https://www.scribd.com/document/649930441/Restore-power-in-case-of-blackout