Part 1: System cardDel 1: Systemkort
1. Core Function
Active Heave Compensated (AHC) offshore knuckle-boom cranes isolate subsea payloads from wave-induced vessel motion by continuously measuring heave, roll, and pitch via Motion Reference Units (MRUs)1. Using surveyed lever-arm coordinate transforms and short-horizon prediction, the controller calculates vertical crane-tip velocity and commands the main hoist winch at equal, opposite speeds—paying out wire as the tip rises and hauling in as it falls1. Overlaying operator lowering inputs onto this closed-loop compensation holds the payload steady relative to the seabed during lowering and landing, within residual lag and wire-elasticity limits1.
2. Primary Operational Tasks
- Real-time vessel heave cancellation: Counteracting vertical crane-tip wave motion through closed-loop winch payout and haul-in to decouple suspended subsea structures from surface sea states1.
- Precision subsea structure landing: Blending slow operator hoist or lower setpoints with active wave cancellation to land payloads onto seabed targets1.
- Constant-tension (CT) splash-zone and seabed lift-off: Maintaining steady line tension during deck or seabed lift-off, splash-zone transit, and set-down handover to prevent slack slings and snap loads4.
- Anti-pendulum tip stabilization: Articulating the knuckle close to the waterline to curtail lateral wire swing, supplemented on modular 3D-compensated cranes by active multi-axis boom control9.
- Dynamic overload protection: Executing automatic (AOPS) or manual (MOPS) controlled winch payout if hook loads exceed structural or overturning limits13.
3. System Interconnections
- Inputs: Vessel-hull MRUs and remote crane-tip or winch motion monitoring units streaming heave, roll, and pitch at up to 200 Hz1; main electrical power supply (AC single-phase, AC three-phase, or DC) or dedicated vessel/crane Hydraulic Power Units (HPUs) (specific HV/LV switchboard architectures are unspecified in consulted sources)18; crane cabin and remote bridge operator consoles, sea-state selectors, and PLCs (specific joystick hardware is not detailed in sources)3; winch drum encoders/position transducers, surveyed lever-arm offsets, and load indicators/calibrated load cells (specific load-pin hardware is omitted in available sources)1.
- Outputs: High-response main/auxiliary hoist, luffing, knuckle, and slewing actuation1; regenerative lowering energy returned to nitrogen-piston hydraulic accumulators, vessel electrical grids, battery/ultracapacitor banks, or dynamic braking resistors1; AOPS/MOPS brake disengagement and controlled overload release paired with 90%, 100%, and 110% SWL visual/audible alarms13; and real-time tip-motion monitoring, hook load/AOPS status displays, and operational data logging4.
4. Redundancy & Criticality
Offshore knuckle-boom cranes operating over open sea are governed by DNV-ST-0378 (with DNV-RP-N202 covering heave-compensation functions and DNV-RP-H201 addressing subsea lifting) alongside API Spec 2C and API RP 2D25. Industry and crane-vendor specifications state that AOPS and MOPS are mandatory for certified ship-to-ship, boat, and off-board lifts (disarmed over fixed platforms) to release overloads via controlled payout without uncontrolled load descent13. Supplementary procurement rules to API Spec 2C (IOGP S-618J and related industry specifications) mandate ISO 12100 / IEC 31010 risk assessments on non-redundant single-line components and require dynamic friction and parking brake redundancy on every load and boom winch so failure of any single brake or drivetrain cannot drop the load19. While dual-point sensing combining hull MRUs with crane-tip monitoring is used commercially1, exact DNV-ST-0378 clauses governing AOPS/MOPS, dual-brake hydraulics, and dual/triple MRU voting were unavailable in the consulted standard excerpts30.
Part 2: Technical deep diveDel 2: Teknisk dybdeanalyse
1. Knuckle-Boom Subsea Crane Geometry & Anti-Pendulum Tip Control
Subsea construction and inspection vessels rely on articulated knuckle-boom cranes—ranging from vendor-specified light/medium units of 15–30 m outreach and 5–100 t SWL up to heavy-lift subsea cranes rated at 250 t single-line or 400 t double-fall with 2,000–4,000+ m drum capacities3—because folding the outer jib brings the boom sheave directly above the deck or close to the water surface. In standard 1D Active Heave Compensation (AHC), the hoist winch cancels only vertical crane-tip motion1. Vessel roll or pitch angle  still translates an elevated crane tip horizontally by
 relative to the roll center, driving lateral pendulum swing across the unsubmerged wire length
 at a natural pendulum period
 1.
Lowering the knuckle tip close to the sea surface sharply reduces both lateral displacement and pendulum resonance alignment with ocean waves. Modeling a 3° vessel roll angle across representative tip heights above a waterline roll center demonstrates the geometric advantage: a high stiff-boom tip at 35.0 m sweeps laterally by 1.83 m with a pendulum period of 11.87 s—squarely inside typical swell periods—whereas lowering a knuckle-boom tip to 15.0 m cuts lateral sweep to 0.79 m (Tp = 7.77 s), and positioning it at 5.0 m slashes lateral sweep by 86% to 0.26 m (Tp = 4.49 s)12. Minimizing this above-water wire length prior to splash-zone entry reduces offlead and sidelead angles (noting IOGP S-618J mandates designing for an additional 0.5° offlead and 0.5° sidelead combined at 100% full value at a 45° crane base angle29), eases deck handling, and lowers lateral impact loads during water entry.
Once the payload enters the sea, hydrodynamic drag and damping quickly suppress lateral swing, enabling 1D vertical AHC paired with the vessel's Dynamic Positioning (DP) system to maintain accurate subsea station31. Above water—such as during offshore wind turbine or ship-to-ship transfers where hydrodynamic damping is absent—1D winch control cannot eliminate horizontal tip swing1. To solve this, anti-sway control systems and modular 3D motion-compensated knuckles (such as exchangeable subsea/3D booms offered by vendors including SMST and Motus) actively coordinate slewing, luffing, and knuckle actuation to stabilize the boom tip in three dimensions, though 3D-compensated lifts carry a lower rating than straight subsea AHC (for example, 5 t in 3D mode versus 15 t in heavy-lift subsea AHC on compact CSOV units)9.
2. Active Heave Compensation (AHC) Control Loops & MRU Kinematics
An AHC crane relies on a high-rate closed feedback loop driven by inertial Motion Reference Units (MRUs) measuring vessel heave, roll, and pitch1. High-precision marine sensors such as Kongsberg's 5th-generation MRU 5 (using mMRG03 MEMS rate gyros) output at 200 Hz with documented 0.005° dynamic roll/pitch accuracy (1-sigma at ±5° amplitude) and real-time heave accuracy of 1 cm or 1% RMS (whichever is highest) at a 10 s period and 5 cm or 5% RMS across 0–25 s periods, while compact industrial units such as Inertial Labs MRUs offer up to 0.01° pitch/roll and 5 cm or 5% heave accuracy17. Crucially, vendor field experience highlights that sensors validated only under idealized sinusoidal lab tests can drift during real irregular seas when coupled surge and sway horizontal accelerations corrupt vertical heave filters15. While remote monitoring sensors near the crane tip or winch are commercially deployed alongside hull MRUs1, explicit dual or triple MRU redundancy voting rules under DNV-ST-0378 were unavailable in the consulted standard excerpts30.
Because MRUs are normally mounted inside the vessel hull rather than on the exposed crane tip, the controller transforms MRU-frame motions across surveyed three-dimensional lever arms to compute exact vertical crane-tip displacement, velocity, and acceleration (whereas remote crane-tip monitoring points reduce or eliminate external lever-arm coordinate transformations)1. The AHC controller then executes four sequential steps many times per second1:
- Signal Filtering & Motion Prediction: High-frequency sensor noise is filtered and tip trajectory is predicted a fraction of a second ahead to compensate for electro-mechanical drive lag1.
- Setpoint Blending: The controller calculates the equal-and-opposite vertical cancellation velocity and sums it with the operator's slow hoist or lower command so the payload moves smoothly relative to the seabed1.
- Feedforward & Closed-Loop Drive Actuation: A feedforward signal—incorporating active drum wire layers, tip velocity, and tip acceleration—commands the electric VFD or hydraulic pump/motor swashplate, using gain-scheduled PID in standard commercial cranes or advanced nonlinear strategies (ADRC, MPC, SMC, LQI, and semi-secondary variable motor control) in research and high-performance architectures24.
- Drum Encoder Closure: Position sensors or encoders on the winch drum feed real-time wire payout back to the controller to close the inner loop1.
Minimizing total loop latency τ—from initial MRU measurement to physical drum motion1—is vital; vendor literature notes modern AHC controllers react within milliseconds2. For sinusoidal heave  delayed by unpredicted latency τ, peak residual hook error follows
 12. Evaluating a ±1.5 m heave amplitude (3.0 m peak-to-peak) demonstrates why keeping latency well under 100 ms alongside predictive filtering is essential12:
Wave Period (T) | τ = 20 ms Error | τ = 50 ms Error | τ = 80 ms Error | τ = 100 ms Error | τ = 200 ms Error |
|---|---|---|---|---|---|
6.0 s (steep sea) | 2.09% (3.1 cm) | 5.24% (7.9 cm) | 8.38% (12.6 cm) | 10.47% (15.7 cm) | 20.91% (31.4 cm) |
8.0 s | 1.57% (2.4 cm) | 3.93% (5.9 cm) | 6.28% (9.4 cm) | 7.85% (11.8 cm) | 15.69% (23.5 cm) |
10.0 s | 1.26% (1.9 cm) | 3.14% (4.7 cm) | 5.03% (7.5 cm) | 6.28% (9.4 cm) | 12.56% (18.8 cm) |
12.0 s (long swell) | 1.05% (1.6 cm) | 2.62% (3.9 cm) | 4.19% (6.3 cm) | 5.24% (7.9 cm) | 10.47% (15.7 cm) |
Source: Unpredicted sinusoidal phase-lag error calculation across wave periods for ±1.5 m heave amplitude12.
Without prediction, a 100 ms delay leaves 15.7 cm of residual heave in a 6 s wave, doubling to 31.4 cm at 200 ms12. Combining low-latency electronics with predictive control enables vendor-claimed heave reduction efficiencies exceeding 95%2, though physical speed/torque limits and short steep seas always leave some residual motion1.
3. Electro-Hydraulic vs. Electric VFD Winch Drives & Energy Recovery
Active heave compensation demands continuous, high-power velocity reversals. For sinusoidal tip motion of amplitude  and period
 , peak speed, acceleration, and drive power satisfy:
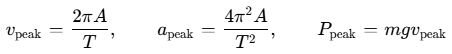
Under a 100 t payload with ±1 m tip heave at a 10 s period, peak speed reaches 0.63 m/s and peak power hits approximately 0.6 MW (~616 kW)1. Multi-fall reeving ( falls) reduces drum line pull by
 and multiplies wire speed by
 , leaving total power (
 ) unchanged while forcing the drum, gearbox, and motors to absorb reversing inertial acceleration (
 ) twice per wave on top of static load torque1. Because the innermost drum layer sets maximum motor speed while the outermost layer sets peak torque, AHC load charts derate lifting capacity below static ratings1. Without energy recovery, lowering work (
 per cycle) turns
 into continuous waste heat in the 100 t benchmark1.
Architecture Parameter | Electro-Hydraulic (Open-Circuit HPU) | Electro-Hydraulic (Closed-Circuit + Accumulator) | Electric VFD (Vector / FOC Drive) |
|---|---|---|---|
Overall & Recovery Efficiency | Low: 10–35% average (50–80% with variable pump + proportional valve) due to throttling losses21 | ≥80% hydrostatic baseline21; recovery varies from 13–15% in small high-pressure saturation rigs33 and ~60–63.4% in crane/CPR designs34 up to 87.7% in isolated accumulator bench tests23 | Highest overall drive efficiency: 70–85% (up to 85–90% in recent reviews)21; 78.7% ultracapacitor bench cycle efficiency23 |
Power Density & Rotor Inertia | Highest actuator power-to-weight (e.g., 167 lb 110 HP hydraulic motor vs. 1,220 lb 100 HP AC motor); minimal inertia21 | Same compact low-inertia hydraulic motor; boot-strap reservoirs can eliminate deck HPUs21 | Lower power-to-weight; large AC rotor inertia can dominate rapid reversal power demands21 |
Dynamic Response & Control | Moderate; non-linear proportional valve flow complicates control tuning21 | Linear speed vs. pump flow, but slower dynamic response than electric drives21 | Superior speed/torque precision and high dynamic bandwidth supporting faster line speeds24 |
Energy Recovery Path | None; lowering potential energy lost as valve throttling heat24 | Direct pumping into nitrogen-piston accumulators or passive gas-spring counterbalances1 | Four-quadrant regeneration to brake resistors, ship grid, or battery/ultracapacitor banks1 |
Thermal & Footprint Trade-offs | Bulky deck HPU; circulating fluid cools components and absorbs shock18 | Compact deck integration; immune to low-speed electrical burnout; oil buffers impacts18 | Eliminates deck oil/hoses, but requires enclosed VFD room and external motor water cooling for sustained low-speed holds18 |
Closed-circuit hydraulic drives couple variable-displacement pumps directly to hydraulic motors without directional throttling valves, allowing four-quadrant energy recovery24. Conventional Variable-Pump Fixed-Motor (VPFM) systems cap usable line speed because motor displacement is fixed for worst-case outer-layer torque, whereas semi-secondary control actively varies motor displacement alongside pump stroke to expand operating speed31. During payout, the payload back-drives the motor as a pump into nitrogen-piston accumulators1. Active/passive hybrids carry static weight on passive gas springs or accumulators, shrinking active heave power from megawatts to kilowatts; in a vendor screening example of a gas-spring-assisted cylinder compensator (90% drive efficiency, 50% regeneration efficiency, 11.6 kW peak drive power, 36.2 kJ returned per cycle), net battery storage across a 10-hour duty fell to 22.1 kWh1. Hydraulic accumulators outperform electrochemical batteries in power density and high-frequency wave cycling without cycle degradation—achieving 87.7% cycle efficiency versus 78.7% for ultracapacitors on comparative test benches23. Still, accumulators are expensive per unit of stored energy for prolonged storage23, pump conversion efficiency limits electric-to-hydraulic charging (peaking near 50% in one rig)23, and small-scale tests show recovery dropping from 15.24% at 500 psi to 13.19% at 1,000 psi when accumulator volume saturates and fluid turbulence rises33.
Electric VFD winches typically pair AC induction or Permanent Magnet Synchronous Motors (PMSMs) with step-down gearboxes21. Replacing early scalar VFDs—which risked torque collapse during abrupt reversals—with Vector (Field-Oriented) Control yields tight velocity tracking and integrated regenerative braking21. Because feeding raw regenerative spikes onto a vessel AC grid can destabilize shipboard systems while brake resistors waste energy as heat1, electric winches increasingly incorporate battery or ultracapacitor banks1. Note that while academic reviews detail VFD grid feedback, batteries, and supercapacitors1, independent benchmarks or architectural details specifically evaluating Active Front End (AFE) converters and shared shipboard DC-bus distribution were unavailable in the consulted sources24. Overall, electric drives provide superior efficiency, precision, and lower lifetime operating costs, whereas closed-circuit hydraulics offer lower upfront capital cost, compact crane-tip/winch actuators, and rugged shock tolerance18.
4. Deep-Water Wire Rope Dynamics, Resonance & AOPS/MOPS Protection
At lowering depths exceeding 3,000 m, rotation-resistant compacted steel wire rope (such as 35x7 or 6x25 IWRC classes) dominates system mass and longitudinal compliance12. Suspended wet weight climbs linearly with paid-out length  39, while longitudinal spring stiffness falls inversely as
 12. Evaluating compacted rotation-resistant steel wire rope (modeled at E_eff = 105 GPa, 0.64 metallic fill factor, and seawater buoyancy factor 0.8694) via Rayleigh's effective mass (
 ) yields the axial natural period
 12:
Wire Rope Case (100 t Subsea Payload + 50 t Added Mass) | Paid-Out Length (L) | Rope Air Mass / Sub. Weight | Axial Stiffness (k) | Payload Static Stretch (Δl) | Axial Natural Period (Tn) | Natural Frequency (fn) |
|---|---|---|---|---|---|---|
76 mm (26.5 kg/m air) | 3,000 m | 79.5 t / 69.1 t | 101.6 kN/m | 9.65 m | 8.28 s | 0.121 Hz |
84 mm (32.5 kg/m air) | 3,000 m | 97.5 t / 84.8 t | 124.1 kN/m | 7.90 m | 7.62 s | 0.131 Hz |
90 mm (37.5 kg/m air) | 3,000 m | 112.5 t / 97.8 t | 142.5 kN/m | 6.88 m | 7.21 s | 0.139 Hz |
84 mm Depth Sweep | 500 m | 16.3 t / 14.1 t | 744.8 kN/m | 1.32 m | 2.87 s | 0.348 Hz |
84 mm Depth Sweep | 1,000 m | 32.5 t / 28.3 t | 372.4 kN/m | 2.63 m | 4.13 s | 0.242 Hz |
84 mm Depth Sweep | 2,000 m | 65.0 t / 56.5 t | 186.2 kN/m | 5.27 m | 6.03 s | 0.166 Hz |
84 mm Depth Sweep | 3,500 m | 113.8 t / 98.9 t | 106.4 kN/m | 9.22 m | 8.35 s | 0.120 Hz |
84 mm Depth Sweep | 4,000 m | 130.0 t / 113.0 t | 93.1 kN/m | 10.54 m | 9.05 s | 0.110 Hz |
Source: Rayleigh longitudinal spring-mass calculations across deep-water rope diameters and payout lengths12.
At 3,000 m, an 84 mm steel rope adds 84.8 t of submerged deadweight—nearly matching a 100 t payload—and stretches 7.90 m elastically under payload weight (11.85 m under 150 t)12. Because a deck winch stabilizes only the top end of this elastic cable1, uncompensated boom-tip motion can excite axial resonance once depth pushes Tn into the 6.03–9.05 s ocean wave band (between 2,000 m and 4,000 m)12. Field experience during Petrobras's 1,860 m manifold lowering40 and variable-domain dynamic modeling up to 3,000 m6 confirm severe resonant tension amplification at critical water depths. Time-varying axial tension combined with continuously changing payout length can also trigger Mathieu-type parametric lateral-axial instability, and transient slackness produces destructive snap loads when tension resumes6. Notably, while stiffer cables shift resonance deeper without substantially altering peak dynamic force6, replacing steel with neutral-buoyancy synthetic fiber rope eliminates rope self-weight escalation6, and effective AHC suppresses top-end excitation to curb resonant amplification44.
If a subsea hook snags on seabed infrastructure during an upward wave heave, high line stiffness (124.1 kN/m at 3,000 m, climbing to 744.8 kN/m at 500 m for an 84 mm rope12) rapidly spikes tension toward boom buckling or vessel overturning13. Crane safety chains pair load indicators and sea-state selectors with tiered alarms at 90%, 100%, and 110% SWL (DNV-ST-0378 [9.4.4] permits relaxing the 90% audible alarm during subsea operations)13. According to vendor functional specifications (as detailed DNV-ST-0378 AOPS/MOPS clauses were unavailable in the consulted standard excerpts30), MOPS warns the operator at a lower threshold to trigger manual winch release13. If overload escalates or strikes abruptly, AOPS automatically engages across all reeving configurations—disengaging hoist and slew brakes, overriding hoist lowering limits, and paying out wire under controlled retaining force sufficient to suspend on-board capacity without uncontrolled load drop13. Manual AOPS override is barred outside man-riding, and the system resets automatically once the overload clears14.
5. Failure Modes, Constant Tension (CT) Mode & Statutory Testing
Safe operational handovers rely on Constant Tension (CT) mode, which regulates winch torque to maintain steady wire pull rather than tracking MRU spatial positions7. Operators engage CT when connecting a hook with slack rigging on a heaving deck or seabed5, during splash-zone transit where earth-fixed AHC ignores passing waves that can buoy payloads into slack-sling snap loads1, and during final seabed landing handover to prevent re-snatching as the vessel moves5. Because CT relies on hydrodynamic payload drag rather than inertial sensing, its positional stability varies strongly with payload size and shape, making AHC preferable during mid-water lowering7.
Prolonged AHC station-keeping subjects crane drivetrains to severe thermal stress. In electric drives, wave-frequency torque reversals at near-zero average speed generate continuous Root-Mean-Square (RMS) motor heating, demanding external water cooling and enclosed VFD rooms1. Although circulating hydraulic oil removes heat and tolerates low-speed high-torque holds better than electric motors18, unrecovered energy dissipation (such as the 196 kW average heat load in the 100 t benchmark1), valve throttling, and high-pressure accumulator turbulence can overheat hydraulic oil unless high-capacity cooling and regenerative accumulators are designed into the crane from the outset33.
Wire rope degradation presents an equally critical failure mode. Continuous wave-frequency bending around boom and winch sheaves accelerates bending fatigue, often restricting intensive subsea wire ropes to five years or less in service38. In an industry failure compilation by IMCA, high spooling tension drove outer wraps to crush into lower drum layers (drum cut-in), forcing premature rope discard from broken strands, while another lifted load dropped after 26 months due to sheave collapse and wire failure despite prior ISO 4309 compliance38. Compacted low-spin ropes improve resistance to drum cut-in, and sheave designs require low-friction bearings with adequate heat dissipation38. Over-lubrication masks visual flaws while under-lubrication accelerates internal corrosion, mandating strict adherence to ISO 4309 and IMCA M 194 discard rules28. Although slack-snap loading6 and low-spin rope selection38 are documented, specific forensic case statistics detailing torsional unlaying and bird-caging failures were unavailable in the consulted inspection reports38.
Statutory verification under DNV-ST-0378, API Spec 2C, API RP 2D, ILO Convention 152, and updated SOLAS lifting appliance regulations (effective 1 January 2026) mandates a 12-month (annual) thorough examination by a competent person alongside proof-load testing at factory completion, post-installation, after major repairs or alterations, and at least every 5 years22. Under DNV-ST-0378 Table 14-1, crane proof-test loads require SWL + 25% up to 20 t, SWL + 5 t from 20 to 50 t, and SWL + 10% above 50 t, while loose gear up to 25 t is tested to 2 × SWL (Table 14-2)26. In offshore pedestal crane execution, API-aligned industry procedures specify verifying test loads via calibrated load cells22 with a 125% SWL static hold (≥10 min) to monitor boom and pedestal deflection for permanent deformation, followed by a 110% SWL dynamic proof test across full hoisting, luffing, and slewing envelopes to validate brakes, limit switches, emergency stops, and AOPS/MOPS test logic14. Across structural design, DNV-ST-0378 applies a dynamic factor ( , minimum 1.3 up to 2,500 kN and 1.1 above 5,000 kN) distinct from the lift-specific Dynamic Amplification Factors (typically 1.3–1.5 on subsea AHC cranes) used in marine operations4.
References
- Active Heave Compensation (AHC): Winches, Cranes, Power, https://nodynamics.com/knowledge-hub/active-heave-compensation/
- AHC Crane Guide for Offshore Lifting in Rough Sea Conditions, https://www.cm-energy.com/knowledge/ahc-crane-guide-for-offshore-lifting-in-rough-sea-conditions
- AHC Cranes - Protea, https://protea.pl/products/ahc-cranes/
- Offshore AHC Cranes - Seaonics, https://www.seaonics.com/products/cranes/ahc-cranes
- DNV GL Marine Warranty Standards - studylib.net, https://studylib.net/doc/26310150/dnvgl-st-n001-marine-operations-and-marine-warranty-compl...
- A Dynamic Model for Continuous Lowering Analysis of Deep-Sea, https://www.mdpi.com/2076-3417/10/9/3177
- Active Heave Compensation - Questions & Answers - Scantrol AS, https://www.scantrol.com/active-heave-compensation-questions-and-answers
- Heave-compensated crane has three-axis stabilisation 1, https://www.rivieramm.com/news-content-hub/news-content-hub/heave-compensated-crane-has-three-axis-stabilisation-1-53319
- Offshore Crane Anti-Sway System | PDF | Kalman Filter - Scribd, https://www.scribd.com/document/371025817/Anti-Sway-Control-and-Wave-Following-for-Offshore-Crane
- Modular crane range - SMST Designers & Constructors BV, https://smstequipment.com/products/modular-crane-range
- Our crane offers a lifting capacity of 5 tons in 3D-mode and ... - Motus, https://www.motustech.no/news/motus-state-of-the-art-3d-compensated-crane-for-two-new-csovs-to-bernhard-schulte-offshore/
- unknown_url
- AOPS and MOPS: Offshore Crane Overload Protection | HEILA, https://heila.com/aops-mops-offshore-crane-overload-protection/
- Automatic Overload Protection System - AOPS, https://www.aanderaa.no/automatic-overload-protection-system-aops
- Active Heave Compensation - Norwegian Subsea, https://norwegian-subsea.no/applications/active-heave-compensation
- Instruction manual Motion reference unit - Kongsberg, https://www.kongsberg.com/globalassets/kongsberg/1.-what-we-do/2.-ocean-space/4.-inertial-solutions/mru/mru-documents/130-0002035a_mru_5th_gen_inm.pdf
- The ideal marine motion sensor - STR subsea, https://www.str-subsea.com/wp-content/uploads/2025/03/388116d_datasheet_mru5_may24.pdf
- Electric vs Hydraulic Offshore Winches | Unique Group, https://www.uniquegroup.com/media-centre/blog-articles/electric-vs-hydraulic-offshore-winch/
- API Specification 2C | PDF - Scribd, https://www.scribd.com/document/585659103/API-Specification-2C
- Subsea Cranes – AHC - Techano Oceanlift, https://techano.no/products/subsea-cranes-ahc/
- https://carleton.ca/mdl/wp-content/uploads/Woodacre_A-review-of-vertical-motion-heave-compensation-systems.pdf
- Load Testing For Modular Offshore Cranes, https://www.thundercranes.com/load-testing-for-modular-offshore-cranes/
- Energy Efficiency Comparison of Hydraulic Accumulators and, https://www.mdpi.com/1996-1073/13/7/1632
- Review of offshore winch drive topologies and control methods, https://vbn.aau.dk/ws/files/484200304/Review_of_offshore_winch_drive_topologies_and_control_methods.pdf
- DNVGL-ST-0378 - Offshore and platform lifting appliances, https://standards.globalspec.com/std/14339711/dnvgl-st-0378
- DNV-ST-0378 (replaced DNV 2.22): Offshore Lifting Appliances, https://nodynamics.com/knowledge-hub/dnv-st-0378-lifting-appliances/
- API RP 2D/2C Offshore Crane Guidelines | PDF - Scribd, https://www.scribd.com/presentation/822196355/2-BUCS-Introducing-API-2D2C-Rev-1-1
- DNV RP-H201 Lifting appliances used in subsea operations, https://www.cranesforyou.com/wp-content/uploads/2024/12/Lifting_appliances_used_in_subsea_operations_DNV-RP-H201.pdf
- Supplementary Specification to API Specification 2C for Offshore, http://jip33.iogp.org/wp-content/uploads/2023/09/Supplementary-Spec-to-API-Specification-2C-for-Offshore-Pedestal-mounted-Cranes-With-JustificatS-618Jv2023-09.pdf
- DNV-ST-0378 Offshore and platform lifting appliances, https://img.antpedia.com/standard/files/pdfs_ora/20230614/DNVGL/DNV-ST-0378-2019%20(2021).pdf
- (PDF) Performance Improvement of a Hydraulic Active/Passive, https://www.researchgate.net/publication/341646519_Performance_Improvement_of_a_Hydraulic_ActivePassive_Heave_Compensation_Winch_Using_Semi_Secondary_Motor_Control_Experimental_and_Numerical_Verification
- Motion Reference Unit (MRU) Datasheet - Inertial Labs, https://www.inertiallabs.com/library/mru_datasheet.pdf
- Experimental evaluation of energy recovery in a hydraulic braking, https://pen.ius.edu.ba/index.php/pen/article/download/1281/1363
- Research on electro-hydraulic composite drive winch and energy, https://www.frontiersin.org/journals/energy-research/articles/10.3389/fenrg.2023.1187558/full
- An Overview of Energy Savings Approaches on Hydraulic Drive, https://journals.riverpublishers.com/index.php/IJFP/article/download/414/2523/11247
- Electric or Hydraulic Energy Recovery Systems in a Reach Truck, https://www.sv-jme.eu/?ns_articles_pdf=/ns_articles/files/ojs/1581/public/1581-8476-1-PB.pdf&id=3133
- 3rd International Naval Architecture and Maritime Symposium - TIB, https://edocs.tib.eu/files/e01mr24/1883007232.pdf
- IMCA High-Value Wire Ropes in the New Offshore Environment, https://www.imca-int.com/media/3qgotrf2/imca-high-value-wire-ropes-in-the-new-offshore-environment-not-just-a-line-on-a-drawing-report-2024.pdf
- Deep-water subsea lifting operations - OSTI, https://www.osti.gov/etdeweb/servlets/purl/993275
- A Model Test for Deepwater Lifting and Lowering Operations of a, http://publications.isope.org/journals/ijope-26-3/abst-26-3-p263-mk49-Nam.pdf
- Parametric resonance avoidance of offshore crane cable in subsea, https://www.researchgate.net/publication/321963733_Parametric_resonance_avoidance_of_offshore_crane_cable_in_subsea_lowering_operation_through_A_Heuristic_planner
- Parametric resonance avoidance of offshore crane cable in subsea, https://diving-rov-specialists.com/index-b-documents_htm_files/os-406-parametric-resonance-avoidance.pdf
- Huisman launches renewed series of subsea Knuckle Boom Cranes, https://www.huismanequipment.com/en/media_centre/press_releases/news_item/163-200_Huisman-launches-renewed-series-of-subsea-Knuckle-Boom-Cranes
- Heave compensation improves offshore lifting operations, https://www.oedigital.com/news/455400-heave-compensation-improves-offshore-lifting-operations
- Failure Analysis of Wire Ropes in Lifting Systems - IRJIET, https://irjiet.com/article/Failure-Analysis-of-Wire-Ropes-in-Lifting-Systems/3168
- New SOLAS regulation for lifting appliances - DNV, https://www.dnv.com/maritime/insights/topics/new-solas-regulation-for-lifting-appliances/
- New safety requirements for onboard lifting appliances from 1 ... - DNV, https://www.dnv.com/news/2025/new-safety-requirements-for-onboard-lifting-appliances-from-1-january-2026/
- Offshore Crane Functional Testing Guide | PDF - Scribd, https://www.scribd.com/document/887310756/Crane-Functional-Test
- Offshore Pedestal Crane Proof Load Testing - Locked Groove, https://lockedgroove.co.uk/offshore-pedestal-crane-proof-load-testing/